
6. Parameter Description – Part 1 (Group P0)
Streszczenie: Opis parametrów KE300 (część 1 z 8): podstawowe funkcje: model, tryb sterowania, źródła poleceń i częstotliwości, limity częstotliwości, częstotliwość nośna, czasy ACC/DEC.
EN: KE300 parameter description (part 1 of 8): basic functions: model, control mode, command and frequency sources, frequency limits, carrier frequency, ACC/DEC times.
Dotyczy: falownik wektorowy Micno KE300 (zasilanie 1AC/3AC 220 V, 3AC 380 V, 3AC 660 V; moce 0,4–630 kW)
Źródło: dokumentacja producenta (Micno KE300 Series Inverter User Manual); tabele przepisane z obrazów na tekst, opisy rysunków – opracowanie Multiprojekt
Nawigacja: część 1 z 8 · następna: następna część (Part 2 (Groups P1–P3)) →
Group P0 Basic Function
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-00 | Inverter model | 1 | 1: G model 2: P model |
1: G model: Applicable to constant torque load.
2: P model: Applicable to constant power load.
KE300 series inverter adopts G/P combination mode, the suitable motor power of constant torque load (G model) is one size smaller than fan and pump loads (P model).
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-01 | Control mode | 0 | 0: V/F control 1: Sensorless vector control |
0: V/F control
It is suitable for general purpose application such as pumps, fans etc. One inverter can drive multiple motors.
1: Sensorless vector control
It is widely used for the application which requires high torque at low speed, high speed accuracy, and quicker dynamic response, such as machine tool, injection molding machine, centrifugal machine and wire-drawing machine, etc.
Note:
The autotuning of motor parameters must be accomplished properly if you use the sensorless vector control. How to autotuning of motor parameters please refer to P4 Group.
In order to achieve better control characteristic, the parameters of vector control (P2 Group) should be adjusted.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-02 | Running command source | 0 | 0: Keypad (LED OFF) 1: Terminal (LED ON) 2: Communication (LED flickers) |
Select the input channel for control command. The inverter control commands include start, stop, forward run, reverse run, Jog and so on.
0: Keypad (“LOCAL/REMOT” LED OFF)
Both RUN and STOP/RST keys are used for running command control. If multifunction key QUICK/JOG is set as FWD/REV switching function (P7-01 is set to be 2), it will be used to change the rotating orientation. If multifunction key QUICK/JOG is set as FWD jog (P7-01 is set to be 3) or REV jog (P7-01 is set to be 4), it will be used for jog running.
1: Terminal (“LOCAL/REMOT” LED ON)
The operations, including FWD, REV, JOGF, JOGR, etc. can be controlled by multifunctional input terminals.
2: Communication (“LOCAL/REMOT” LED flickers)
The operation of inverter can be controlled by host through communication.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-03 | Main frequency source A selection | 0 | 0: Keypad (P0-08, UP and DOWN adjustable, not stored when power-off) 1: Keypad (P0-08, UP and DOWN adjustable, stored when power-off) 2: AI1 3: AI2 4: Keypad potentiometer 5: High speed PULSE (HDI) 6: Multi-step speed 7: Simple PLC 8: PID 9: Communication |
0: Keypad (not store)
The initial value is the value of P0-08. The setting frequency value of inverter can be modified through the keys “▲” and “▼” of the keyboard (or UP and DOWN of multifunctional input terminals).
“Not store” means that the setting frequency is recovered to the value of P0-08 in case of inverter poweroff.
1: Keypad (store)
The initial value is the value of P0-08.
“Store” means that the setting frequency remains the same as the value before inverter power-off.
2: Al1
3: Al2
The reference frequency is set by analog input. KE300 series inverter provides 2 analog input terminals (AI1, AI2). Both of AI1 and AI2 are 0~10V / 0~20mA input terminal.
User can select the corresponding relation between the objective frequency and the input voltage value of AI freely. KE300 series inverter provides 3 corresponding relation curves which can be set by users through P4 group function code.
4: Keypad potentiometer
The reference frequency is set by keypad potentiometer.
5: High speed PULSE (HDI)
The reference frequency is set by high speed pulse.
Pulse reference signal specification: the voltage range is 9V to 30V, and the frequency range is 0kHz to 50kHz. Pulse given can only be input from the multifunctional input terminal HDI.
6: Multi-step speed
The reference frequency is determined by P4 and PC groups. The selection of steps is determined by combination of multi-step speed terminals.
7: Simple PLC
User can set reference frequency, hold time, running direction of each step and acceleration/deceleration time between steps. For details, please refer to description of PC group.
8: PID
The reference frequency is the result of PID adjustment. For details, please refer to description of PA group.
9: Communication
The reference frequency is set through RS485. For details, please refer to Modbus protocol in Chapter 9.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-04 | Auxiliary frequency source B selection | 0 | 0: Keypad (P0-08, UP and DOWN adjustable, non-recorded) 1: Keypad (P0-08, UP and DOWN adjustable, recorded) 2: AI1 3: AI2 4: Keypad potentiometer 5: High speed PULSE (HDI) 6: Multi-step speed 7: Simple PLC 8: PID 9: Communication |
When the auxiliary frequency source is used as independent frequency reference channel (i.e. frequency source switching from A to B), it is used in the same way as the main frequency source. Please refer to P0-03.
When the auxiliary frequency source is used as combination reference, please note:
- If the auxiliary frequency source is keypad reference, the frequency (P0-08) is invalid, and it needs to adjust the main reference frequency through the keys “▲”and “▼” of the keyboard (or UP and DOWN of multifunctional input terminals).
- If the auxiliary frequency source is analog input reference (AI1, AI2) or pulse input reference, 100% of input corresponds to the auxiliary frequency source range (refer to P0-05 and P-06).
- If the frequency source is pulse input reference, it is similar to the analog input reference.
Note: P0-03 and P0-04 can’t be set to be the same value. Otherwise, disorder will occur.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-05 | Frequency source B reference | 0 | 0: Relative to maximum frequency 1: Relative to frequency source A |
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-06 | Auxiliary frequency source B range | 100% | 0% ~ 150% |
When the frequency source selection is frequency combination reference (P0-07 is set to 1 or 3), the two parameters are used to determine the adjustment range of auxiliary frequency source.
P0-05 is used to determine the relative object of that range. If it is relative to maximum frequency A, that range will change with the main frequency A.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-07 | Frequency source selection | 00 | Units place – frequency source selection: 0: Main frequency source A 1: Calculation result of frequency A and B (determined by tens place) 2: Switching between A and B 3: Switching between A and calculation result 4: Switching between B and calculation result Tens place – calculation relationship between frequency A and B: 0: A + B 1: A - B 2: Max (A, B) 3: Min (A, B) |
Units place: Frequency source selection
0: Main frequency source A
Reference frequency = A
1: Calculation result of frequency A and B
Reference frequency = Calculation result of frequency A and B (determined by tens place)
2: Switching between A and B
If the multifunctional input terminal HDI (P4-0X=18:frequency switching) is invalid, reference frequency = A.
If the multifunctional input terminal HDI (frequency source switching) is valid, reference frequency = B.
3: Switching between A and calculation result
If the multifunctional input terminal HDI (frequency switching) is invalid, reference frequency = A.
If the multifunctional input terminal HDI (frequency switching) is valid, reference frequency = calculation result.
4: Switching between B and calculation result
If the multifunctional input terminal HDI (frequency switching) is invalid, reference frequency = B.
If the multifunctional input terminal HDI (frequency switching) is valid, reference frequency = calculation result.
Tens place: Frequency source main/auxiliary calculation relationship
0: A + B
Reference frequency = A + B, achieving frequency combination given function.
1: A - B
Reference frequency = A - B
2: Max (A, B)
Reference frequency = Max (A, B)
3: Min (A, B)
Reference frequency = Min (A, B)
Note: When the frequency source selection is main/auxiliary calculation, the preset offset frequency can be set via P0-21, which can be added to main/auxiliary calculation result to meet different kinds of demand.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-08 | Keypad reference frequency | 50.00Hz | 0.00 ~ P0-10 (maximum frequency) |
When the main frequency source is selected as “Keypad” or “Terminals UP/DN”, this function code is the initial value of frequency digital setting of the inverter.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-09 | Running direction | 0 | 0: Direction is forward 1: Direction is reverse |
Through modifying this function code, it can change the rotary direction of the motor without changing motor wiring. It’s equal to adjust any two lines of the motor (U, V and W) and further change the rotary direction of the motor.
Note: If the parameters are restored, the running direction will be back to its original status.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-10 | Maximum frequency | 50.00Hz | 50.00Hz ~ 300.00Hz |
The maximum output frequency of KE300 series inverter is 3000Hz.
When P0-22 is set to 1, frequency resolution is 0.1Hz, P0-10 setting range is 50.0Hz~3000.0Hz;
When P0-22 is set to 2, frequency resolution is 0.01Hz, P0-10 setting range is 50.0Hz~300.0Hz.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-11 | Frequency source upper limit | 0 | 0: P0-12 setting 1: AI1 2: AI2 3: Keypad potentiometer 4: HDI PULSE 5: Communication |
It is used to define the source of frequency upper limit. The frequency upper limit can be sourced from either digital setting (P0-12) or analog input. When the analog input is used to set the frequency upper limit, 100% of analog input setting is relative to P0-12.
Notice:
Upper frequency limit should exceed than the maximum frequency.
Output frequency should not exceed upper frequency limit.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-12 | Frequency upper limit | 50.00Hz | P0-14 (frequency lower limit) ~ P0-10 (maximum frequency) |
| P0-13 | Frequency upper limit offset | 0.00Hz | 0.00Hz ~ P0-10 (maximum frequency) |
When the frequency source upper limit is analog value or HDI pulse, P0-13 is used as the setting value’s offset. The combination of this offset frequency and P0-12 is used as the final setting value of frequency upper limit.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-14 | Frequency lower limit | 0.00Hz | 0.00Hz ~ P0-12 (frequency upper limit) |
If the reference frequency is lower than frequency lower limit, the inverter can stop, or run with lower limit frequency, or run at zero speed, which is set by P8-14.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-15 | Carrier frequency | Model dependent | 1.0kHz ~ 16.0kHz |
Carrier frequency will affect the noise of motor and the EMI of inverter.
If the carrier frequency is increased, it will cause better current wave, less harmonic current and lower noise of motor.
Notice:
The factory default is optimal in most cases. Modification of this parameter is not recommended. If the carrier frequency exceeds the factory default, the inverter must be derated because the higher carrier frequency will cause more switching loss, higher temperature rise of inverter and stronger electromagnetic interference.
If the carrier frequency is lower than the factory default, it is possible to cause less output torque of motor and more harmonic current.
The effect of modifying carrier frequency is as following
Effect of the carrier frequency
| Item | Carrier frequency: low → high |
|---|---|
| Motor noise | High → Low |
| Output current waveform | Poor → Good |
| Motor temperature rise | High → Low |
| Inverter temperature rise | Low → High |
| Leakage current | Small → Big |
| External radiation interference | Small → Big |
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-16 | Carrier frequency adjusting according to temperature | 1 | 0: No 1: Yes |
The inverter can automatically adjust the carrier frequency according to its temperature. This function can reduce the possibility of overheat alarm of the inverter.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-17 | Acceleration time 1 | Model dependent | 0.00s ~ 36000s |
| P0-18 | Deceleration time 1 | Model dependent | 0.00s ~ 36000s |
Acceleration time is the time of accelerating from 0Hz to ACC/DEC time reference frequency (P0-25).
Deceleration time is the time of decelerating from ACC/DEC time reference frequency (P0-25) to 0Hz.
Please refer to following figure.
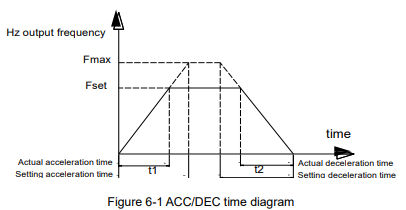
Diagram description (text version): Figure 6-1 ACC/DEC time diagram: the output frequency (Hz) rises linearly from 0 to the set frequency Fset and later falls back to 0. The setting acceleration time is the time to rise from 0 to the maximum frequency Fmax, the setting deceleration time the time to fall from Fmax to 0; the actual acceleration time t1 and actual deceleration time t2 are proportionally shorter when Fset is lower than Fmax.
There are totally four groups of acceleration/deceleration time which can be selected via the multifunctional digital input terminals.
Group 1: P0-17, P0-18;
Group 2: P8-03, P8-04;
Group 3: P8-05, P8-06;
Group 4: P8-07, P8-08.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-19 | ACC/DEC time unit | 1 | 0: 1s 1: 0.1s 2: 0.01s |
KE300 series inverter offers three ACC/DEC time units, they are 1s, 0.1s, 0.01s.
Note: When modifying this function parameter, 4 group ACC/DEC time display decimal place changes, the corresponding ACC/DEC time also changes.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-21 | Auxiliary frequency source offset frequency when combination | 0.00Hz | 0.00Hz ~ P0-10 (maximum frequency) |
This function code is only valid when frequency source is set to be main/auxiliary calculation.
When frequency source is set to be main/auxiliary calculation, P0-21 is offset frequency, which can be combined with main/auxiliary calculation result setting as reference frequency.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-22 | Frequency command resolution | 2 | 1: 0.1Hz 2: 0.01Hz |
This parameter is used to determine the resolution of all the function codes related to frequency.
When frequency resolution is 0.1Hz, the MAX. output frequency is 3000.0Hz. When frequency resolution is 0.01Hz, the MAX. output frequency is 300.00Hz.
Note: When modifying this parameter, the decimal place of all the parameters related to frequency changes, the corresponding frequency value changes too.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-23 | Digital setting frequency storage selection when stop | 1 | 0: Not store 1: Store |
This function is only valid when frequency source is set by keypad
0: No store means that the keypad setting frequency value would recover to the value of P0-08 (preset frequency) after the inverter stopped. The frequency modification by keys “▲”, “▼” or terminal UP, DOWN would be cleared.
1: Store means that the keypad setting frequency would recover to the last frequency when inverter stopping. The frequency modification by keys “▲”, “▼” or terminal UP, DOWN is valid.
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-25 | ACC/DEC time reference frequency | 0 | 0: P0-10 (maximum frequency) 1: Setting frequency 2: 100Hz |
ACC/DEC time is ACC/DEC time from 0Hz to the frequency set by P0-25, figure 6-1 is ACC/DEC time schematic diagram.
When P0-25 is set to 1, ACC/DEC time is related to setting frequency. The motor acceleration will change if setting frequency changes frequently
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-26 | Running frequency command UP/DN reference | 0 | 0: Running frequency 1: Setting frequency |
This parameter is only valid when frequency source is set by keypad.
It is used to confirm which mode would be used to modify setting frequency when keys “▲”, “▼” or terminal UP, DOWN acts, namely, whether reference frequency increases/decreases on the basic of running frequency, or increases/decreases on the basic of setting frequency
| Parameter | Name | Factory default | Setting range |
|---|---|---|---|
| P0-27 | Command source combination with frequency source | 000 | Units place – operation keypad command combination with frequency source: 0: No combination 1: Keypad setting frequency 2: AI1 3: AI2 4: Keypad potentiometer 5: High speed pulse HDI 6: Multi-step speed 7: Simple PLC 8: PID 9: Communication Tens place – terminal command combination with frequency source (0 ~ 9, same as units place) Hundreds place – communication command combination with frequency source (0 ~ 9, same as units place) |
Defining the combination between three running command channels and nine frequency given channels, it’s convenient to achieve synchronous switching.
The meaning of the above frequency given channels is the same as the selection of the main frequency source A (P0-03). Please refer to P0-03.
Different running command channels can bind the same frequency given channel.
When command source binds frequency source & command source is valid, the frequency source set by P0-03 ~ P0-07 is invalid.
Słowa kluczowe
Micno KE300, opis parametrów, parameter description, P0, tryb sterowania, control mode, źródło częstotliwości, frequency source, P0-03, P0-10, częstotliwość nośna, carrier frequency, czas przyspieszania, acceleration time