
7. Command Inputs
Streszczenie: Źródła sygnału zadającego: wejście analogowe (skalowanie, strefa martwa, offset), wejście PWM (formaty 50% i 100% z kierunkiem), cyfrowe wejścia pozycji (impuls/kierunek, impulsy góra/dół, kwadratura A/B) oraz wartości programowane (pozycja, prędkość, prąd); zawiera opisy tekstowe przebiegów czasowych.
EN: Command inputs: analog, PWM, digital position (pulse/direction, up/down, quadrature) and software-programmed inputs.
Dotyczy: program CME 2 do konfiguracji i strojenia serwonapędów oraz napędów krokowych Copley Controls (m.in. Xenus, Accelnet, Stepnet, Accelus, Junus)
Źródło: dokumentacja producenta (Copley Controls CME 2 User Guide); tabele przepisane z obrazów na tekst, opisy diagramów – opracowanie Multiprojekt
This chapter shows how to configure the amplifier’s command inputs. Perform the basic steps outlined below. Details follow in the chapter.
1.  or
 or
 or
 or
 or
 or
Click to open the loop command input settings screen.
2. Change/verify command input parameters as described in the following sections:
- Analog Command Settings
- PWM Input Settings
- Digital Position Input Settings or
- CAN Network Configuration
- Software Programmed Input Settings
- Copley Camming User Guide
3. Click Close to close screen and save changes to amplifier RAM.
7.1 Analog Command Settings
View or change the settings described below.
Analog Command – parameters
| Parameter | Description |
|---|---|
| Scaling | Current mode: output current produced by +10 Vdc of input. Range: 0 to 10,000,000 A. Default: Peak Current value. Velocity mode: output velocity produced by +10 Vdc of input. Range: 0 to 100,000 rpm (mm/sec). Default: Maximum Velocity value. Position mode: position change (counts or mm) produced by +10 Vdc of input. Range: 0 to 1,000,000,000 counts. Default: 1 Revolution of a rotary motor or 1 pole pair distance for a linear motor. For more information, see Scaling. |
| Dead Band | Sets dead band. Range: -10,000 to 10,000 mV. Default: 0. For more information, see Dead Band. |
| Invert Command | Inverts polarity of amplifier output with respect to input signal. |
| Offset | (Current and Velocity modes only.) Used to offset input voltage error in an open loop system. Not recommended for use when the amplifier is part of a closed loop system. Range: -10,000 to 10,000 mV. Default: 0. For more information, see Offset. |
| Analog Input Filter | Programmable input filter. Disabled by default. See Low-Pass and Bi-Quad Filters. |
| For more information, see Analog Command Notes. | |
7.1.1 Analog Command Notes
The amplifier can be driven by an analog voltage signal through the analog command input. The amplifier converts the signal to a current, velocity, or position command as appropriate for current, velocity, or position mode operation, respectively. The analog input signal is conditioned by the scaling, dead band, and offset settings.
Scaling
The magnitude of the command generated by an input signal is proportional to the input signal voltage. Scaling controls the input-to-command ratio, allowing the use of an optimal command range for any given input voltage signal range.
For example, in current mode, with default scaling, +10 Vdc of input generates a command equal to the amplifier’s peak current output; +5 Vdc equals half of that.
Scaling could also be useful if, for example, the signal source generates a signal range between 0 and +10 Vdc, but the command range only requires +7.5 Vdc of input. In this case, scaling allows the amplifier to equate +7.5 Vdc with the amplifier’s peak current (in current mode) or maximum velocity (in velocity mode), increasing the resolution of control.
Dead Band
To protect against unintended response to low-level line noise or interference, the amplifier can be programmed with a “dead band” to condition the response to the input signal voltage. The amplifier treats anything within the dead band ranges as zero, and subtracts the dead band value from all other values. For instance, with a dead band of 100 mV, the amplifier ignores signals between –100 mV and +100 mV, and treats 101 mV as 1 mV, 200 mV as 100 mV, and so on.
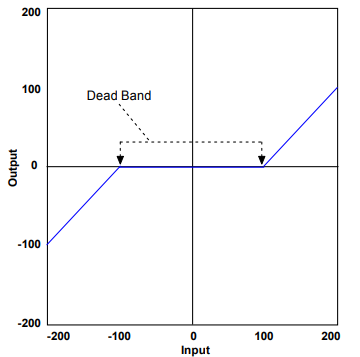
Diagram description (text version): Dead band characteristic of the analog command: Output (vertical axis, -100…200) versus input voltage. Inside the dead band around zero the output is 0; outside it the output rises linearly, offset by the dead band – e.g. with a 100 mV dead band an input of 101 mV is treated as 1 mV and 200 mV as 100 mV (symmetrically for negative inputs).
Offset
To remove the effects of voltage offsets between the controller and the amplifier in open loop systems, CME 2 provides an Offset parameter and a Measure function. The Measure function takes 10 readings of the analog input voltage over a period of approximately 200 ms, averages the readings, and then displays the results. The Offset parameter allows the user to enter a corrective offset to be applied to the input voltage. The offset can also set up the amplifier for bi-directional operation from a uni-polar input voltage. An example of this would be a 0 to +10 Vdc velocity command that had to control 1000 rpm CCW to 1000 rpm CW. Scale would be set to 2000 rpm for a +10 Vdc input and Offset set to -5V. After this, a 0 Vdc input command would be interpreted as -5 Vdc, which would produce 1000 rpm CCW rotation. A +10 Vdc command would be interpreted as +5 Vdc and produce 1000 rpm CW rotation.
Monitoring the Analog Command Voltage
The analog input voltage can be monitored in the Control Panel and in the Scope Tool. The voltage displayed in both cases is after both offset and deadband have been applied.
Analog Command in Position Mode
The Analog Position command operates as a relative motion command. When the amplifier is enabled the voltage on the analog input is read. Then any change in the command voltage will move the axis a relative distance, equal to the change in voltage, from its position when enabled. To use the analog position command as an absolute position command, the amplifier should be homed every time it is enabled. The Homing sequence may be initiated by CAN, ASCII serial, DeviceNet, or CVM Indexer program commands.
7.2 PWM Input Settings
View or change the settings described below.
PWM Command – parameters
| Parameter | Description |
|---|---|
| Scaling | Current mode: output current at 100% duty cycle. Range: 0 to 10,000,000 A. Default: Peak Current value. Velocity mode: output velocity at 100% duty cycle. Range: 0 to 100,000 rpm (mm/sec). Default: Maximum Velocity value. |
| PWM Input Type | One wire 50% or two wire 100% with direction. |
| Options | Invert PWM input: Inverts the PWM logic. Allow 100% output: Overrides the 100% command safety measure, see Failsafe Protection from 0 or 100% Duty Cycle Commands. Invert Sign Input: In 100% duty cycle mode, inverts the polarity of the directional input. |
| For more information, see PWM Input Notes. | |
7.2.1 PWM Input Notes
Two Formats
The amplifier can accept a pulse width modulated signal (PWM) signal to provide a current command in current mode and a velocity command in velocity mode. The PWM input can be programmed for two formats: 50% duty cycle (one-wire) and 100% duty cycle (two-wire).
50% Duty Cycle Format (One-Wire)
The input takes a PWM waveform of fixed frequency and variable duty cycle. As shown below, a 50% duty cycle produces zero output from the amplifier. Increasing the duty cycle toward 100% commands a positive output, and decreasing the duty cycle toward zero commands a negative output.
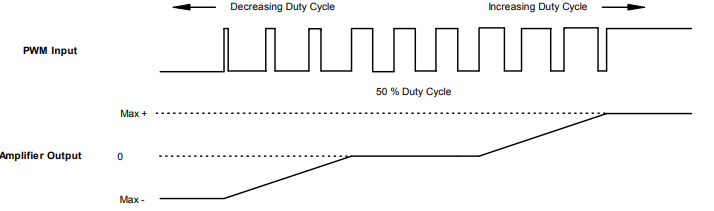
Diagram description (text version): PWM input, 50% duty cycle format (one wire): the PWM Input signal is shown with a duty cycle decreasing to the left and increasing to the right. At 50% duty cycle the Amplifier Output is 0; increasing the duty cycle toward 100% raises the output toward Max +, decreasing it toward 0% drives the output toward Max -.
The command can be inverted so that increased duty cycle commands negative output and vice versa.
100% Duty Cycle Format (Two-Wire)
One input takes a PWM waveform of fixed frequency and variable duty cycle, and the other input takes a DC level that controls the polarity of the output. A 0% duty cycle creates a zero command, and a 100% duty cycle creates a maximum command level. The command can be inverted so that increasing the duty cycle decreases the output and vice versa.
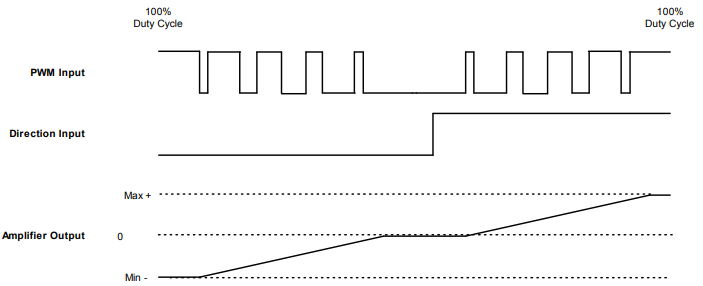
Diagram description (text version): PWM input, 100% duty cycle format (two wires: PWM + Direction): the PWM Input sets the magnitude and the Direction Input sets the sign. With the Direction Input low the output is negative – 100% duty cycle gives Min -, and the output rises to 0 as the duty cycle falls to 0%. After the Direction Input switches high, increasing the duty cycle toward 100% raises the Amplifier Output from 0 to Max +.
Failsafe Protection from 0 or 100% Duty Cycle Commands
In both formats, the amplifier can be programmed to interpret 0 or 100% duty cycle as a zero command, providing a measure of safety in case of controller failure or cable break.
7.3 Digital Position Input Settings
View or change the settings described below.
Digital Position Inputs – settings
| Parameter | Description |
|---|---|
| Control Input | Pulse and Direction: one input takes a series of pulses as motion step commands, and another input takes a high or low signal as a direction command. Pulse Up / Pulse Down: one input takes each pulse as a positive step command, and another takes each pulse as a negative step command. Quadrature: A/B quadrature commands from a master encoder (via two inputs) provide velocity and direction commands. |
| Increment position on | Rising Edge: increment position on the rising edge of the input pulse. Falling Edge: increment position on the falling edge of the input pulse. |
| Stepping Resolution | Input Pulses: number of Input Pulses required to produce output counts. Range: 1 to 32,767. Default: 1. Output Counts: number of Output Counts per given number of input pulses. Range: 1 to 32,767. Default: 1. |
| Invert Command | When selected, inverts commanded direction. |
For more information, see Digital Position Input Notes.
7.3.1 Digital Position Input Notes
Three Formats
In position mode, the amplifier can accept position commands using one of these signal formats: pulse and direction, count up/count down, and quadrature. In all three formats, the amplifier can be configured to invert the command.
Pulse Smoothing
In digital position mode, the amplifier’s trajectory generator can be used to create trapezoidal profiles, with programmed acceleration, deceleration and velocity, from a simple pulse train or burst of pulses To bypass the trajectory generator while in digital or analog position modes, set the maximum acceleration to zero. The only limits in effect will now be the velocity loop velocity limit and the current limits. (Note that leaving the maximum acceleration set to zero will prevent other position modes from operating correctly.)
Pulse and Direction Format
In pulse and direction format, one input takes a series of pulses as motion step commands, and another input takes a high or low signal as a direction command, as shown below.
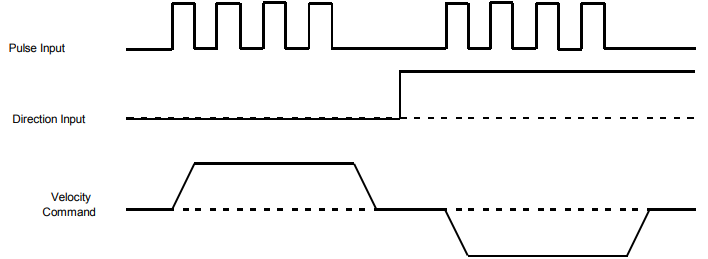
Diagram description (text version): Pulse and Direction input: each pulse on the Pulse Input is a step command and the Direction Input sets the direction. While the Direction Input is low, the pulse train produces a positive Velocity Command; after the Direction Input switches high, the next pulse train produces a negative Velocity Command (the dashed line marks zero velocity).
The amplifier can be set to increment position on the rising or falling edge of the signal. Stepping resolution can be programmed for electronic gearing.
Count Up/Count Down Format
In the count up/count down format, one input takes each pulse as a positive step command, and another takes each pulse as a negative step command, as shown below
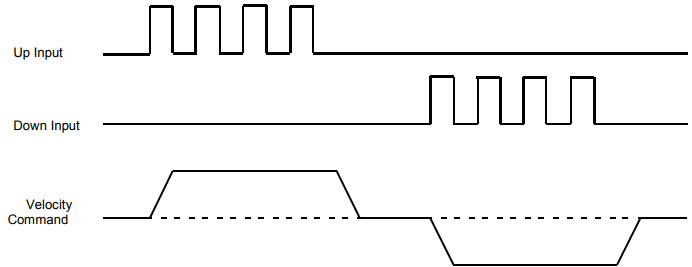
Diagram description (text version): Pulse Up / Pulse Down input: pulses on the Up Input are counted as positive steps and produce a positive Velocity Command; pulses on the Down Input are counted as negative steps and produce a negative Velocity Command (the dashed line marks zero velocity).
The amplifier can be set to increment position on the rising or falling edge of the signal. Stepping resolution can be programmed for electronic gearing.
Quadrature Format
In quadrature format, A/B quadrature commands from a master encoder provide velocity and direction commands, as shown below.
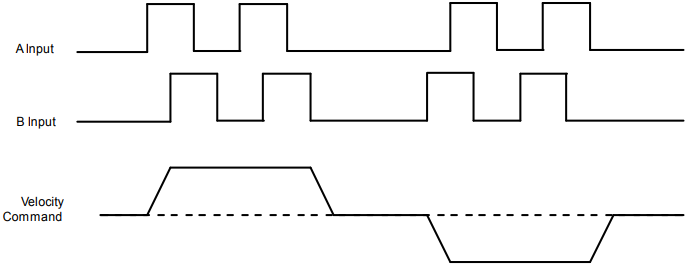
Diagram description (text version): Quadrature (A/B) input from a master encoder: when the A Input leads the B Input, the Velocity Command is positive; when the B Input leads the A Input, the Velocity Command is negative. The pulse frequency sets the speed (the dashed line marks zero velocity).
The ratio can be programmed for electronic gearing
7.4 Software Programmed Input Settings
These settings can be saved to flash to allow default conditions to be set and used when the amplifier is powered up or reset.
DANGER: Potential for unexpected movement
If Programmed Velocity or Programmed Current are set to values other than 0, the motor will move after power-up or reset if the amplifier is hardware enabled.
Failure to heed this warning can cause equipment damage, injury, or death.
7.4.1 Programmed Position
View or change the settings described below.
Programmed Position – settings
| Setting | Description |
|---|---|
| Move | Relative or Absolute. |
| Type | Trap or S-Curve. |
| Distance | Move distance. |
7.4.2 Programmed Velocity
View or change the setting described below.
Programmed Velocity – settings
| Setting | Description |
|---|---|
| Programmed Velocity | Move velocity. Units: rpm (rotary) or mm/s (linear). |
7.4.3 Programmed Current
View or change the settings described below.
Programmed Current – settings
| Setting | Description |
|---|---|
| Programmed Current | Current applied during the constant velocity portion of the move. Units: A. |
| Current Ramp | Acceleration/deceleration current. Units: mA/s. |
Słowa kluczowe
wejście analogowe, skalowanie, strefa martwa, offset, PWM, wypełnienie, impuls/kierunek, pulse up/down, kwadratura, enkoder master, programmed position, programmed velocity, programmed current
No comments to display
No comments to display